Benjamin Taoson赖建铭

BENJAMIN TAOSON / DIGITAL AI × PHYSICAL AI

作品与研究Work & Research

从数字世界到物理世界:大模型、Agent 与机器人学习的项目、实验和设计取舍。From digital AI to robotics: projects, experiments, and engineering decisions around models and agents.

DIGITAL AI工程案例Engineering case study

AI BA · 企业经营分析AI BA · Business Analytics

把业务提问变成能追溯到数据的分析报告:从门店销售中定位驱动因素,给出发现、依据与下一步建议。Turn a business question into a report you can trace to the data: investigate store sales, identify drivers, and connect findings to evidence and next steps.

原始问题Original question · translated

分析最近一期经营表现,找出最值得管理层关注的问题和机会,解释原因,并告诉我下一步应该做什么。Analyze the latest business performance, identify the issues and opportunities management should prioritize, explain why, and recommend the next action.

报告发现Finding

门店 429 × COUPON/MISC ITEMS 的销售额减少 $377.29。Store 429 × COUPON/MISC ITEMS: sales decreased by $377.29.

第 52–53 周,对比第 50–51 周Weeks 52–53 versus weeks 50–51

报告建议的下一步Recommended next step

先检查该门店与品类的商品、促销和供给代理指标,再决定是否采取大范围调整。Inspect product, promotion and availability proxies for store 429 within COUPON/MISC ITEMS before applying a broad intervention.

公开数据上的确定性规划与分析;报告建议尚未执行,实际业务效果未评估。Deterministic planning and analysis on public data. Report recommendations were not executed; business impact was not evaluated.

选择策略消融实验Finding-selection ablation

+10 pp驱动召回率 · 同输出、10 案例消融Driver recall · same outputs, 10 cases

Driver Recall@K 从 90% 到 100%;只比较同一批分析结果的选择策略,不能解释为营收提升。Driver Recall@K rises from 90% to 100% when selecting from the same analysis outputs. This is a selection-policy comparison, not a revenue increase.
DIGITAL AI多模态研究Multimodal research

RewardLensRewardLens

模型真的在看图吗?固定问题和答案选项,只改变画面中的一个因素,检查模型是否跟随了正确的变化。Is the model reading the image? Keep the question and answer choices fixed, change one visual factor, and check whether its response changes for the right reason.

RewardLens · 实验样例RewardLens · Experiment example

只改一处,答案该不该变?Change one detail. Should the answer change?

问题与候选答案始终不变。切换三张已保存的实验图,比较正确答案与模型当时的输出。The question and candidate answers stay fixed. Compare three saved experiment images, their expected answers, and the model’s recorded outputs.

固定问题:Fixed question: 立方体是什么颜色?What color is the cube?

固定候选:Fixed candidates: A · 蓝色(blue)blueB · 红色(red)red

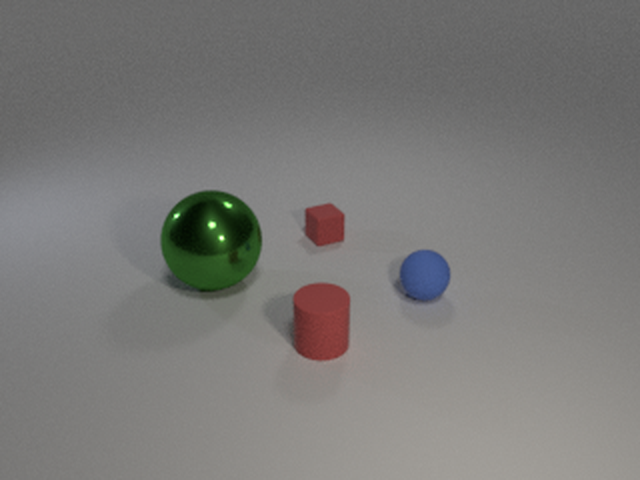
仿真场景:红色立方体、红色圆柱体、红色小球和绿色金属球。
原图Original

立方体是红色。先看模型能否回答原始问题。The cube is red. First, check the model’s answer to the original question.

预期答案Expected answer
B · 红色red
Molmo-7B-D 已保存的输出recorded output
B · 红色red

与预期一致Matches the expected answer

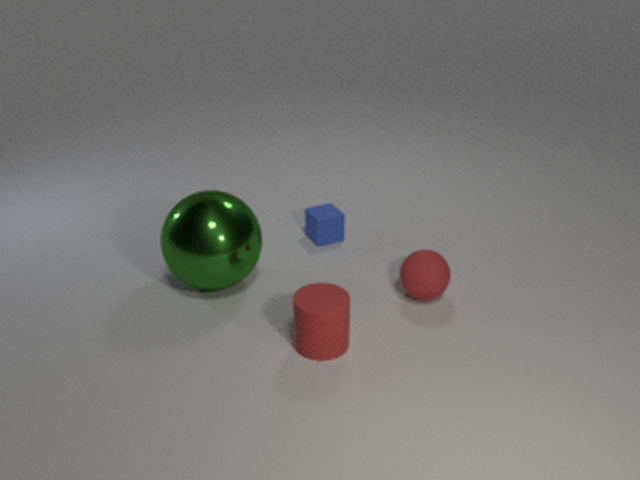
同一仿真场景,只有立方体由红色变为蓝色。
改立方体Edit the cube

只把立方体从红色改成蓝色。正确答案应该随证据改变。Only the cube changes from red to blue. The correct answer should change with the evidence.

预期答案Expected answer
A · 蓝色blue
Molmo-7B-D 已保存的输出recorded output
A · 蓝色blue

与预期一致Matches the expected answer

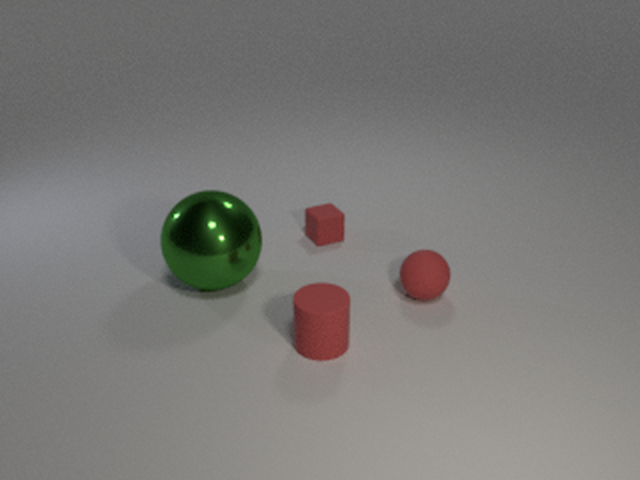
同一仿真场景,只有右侧小球由红色变为蓝色,立方体仍为红色。
改旁边的球Edit the sphere

只把右侧球体从红色改成蓝色,立方体仍是红色。正确答案应该保持不变。Only the sphere on the right changes from red to blue; the cube stays red. The correct answer should stay the same.

预期答案Expected answer
B · 红色red
Molmo-7B-D 已保存的输出recorded output
A · 蓝色blue

与预期不符Does not match the expected answer

这个例子里,模型跟随了立方体的颜色变化,却也被与问题无关的球体颜色变化带偏。RewardLens 分别检查这两种行为。In this example, the model follows the cube’s color change, but also changes its answer when only an irrelevant sphere changes. RewardLens checks these two behaviors separately.

一个已保存的仿真样例 · 离线输出,不代表总体准确率。One saved simulation example · Offline outputs, not overall accuracy.

来源与适用范围Sources and scope

这是一个已保存的仿真实验样例及离线模型输出,不是实时推理,也不代表模型的总体准确率。模型接收的原始问题与候选均为英文;中文是页面释义。These are saved simulation images and offline model outputs, not live inference or an estimate of overall model accuracy. The original question and candidates were in English; Chinese text is a page translation.

样例 attr_000000;三幅图由公开附录拼图按原像素提取,与同一条目编号的标签及输出对应。Example attr_000000. The three images are exact pixel crops from the public appendix montage, matched to labels and outputs with the same item IDs.

静态同分下的行为差异Behavior at a static-accuracy tie

15.1 ppAttribute 静态平分下的 RA 差异RA gap at an exact Attribute static tie

Attribute:两模型静态准确率均为 80.5%;RA 分别按各自原图正确子集计算。此汇总对比与上面的 Molmo 单例使用不同模型。Attribute: both judges score 80.5% static accuracy; RA uses each judge’s own base-correct subset. This aggregate comparison uses different models from the Molmo example above.

PHYSICAL AI机器人决策仿真原型Robot-decision simulation prototype

SpatialMindSpatialMind

机器人记得目标曾在哪里,也要确认它现在是否仍在那里;通过观察、记忆更新与重规划完成找物任务。A robot remembers where a target was, then checks whether it is still there: observations, memory updates, and replanning guide the search.

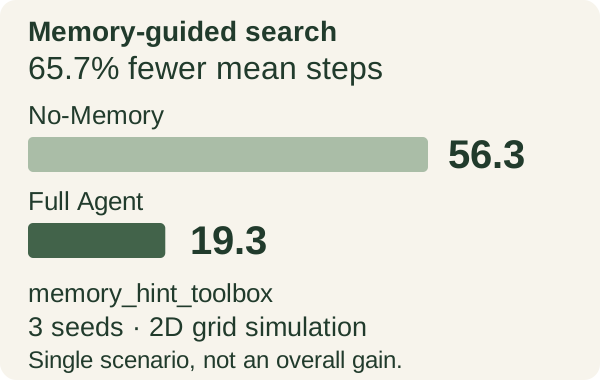
memory_hint_toolbox 单场景、3 个种子、二维网格仿真:无记忆平均 56.3 步,完整策略 19.3 步,减少 65.7%;不代表全部任务或真机性能。
让历史记忆指导搜索,再用当前观察确认目标。图示为固定场景的三种子对照实验。Use memory to guide search and current observations to confirm the target. The chart compares three seeds in one fixed scenario.

空间记忆搜索与消融Memory-guided search and ablation

65.7%历史位置线索场景的平均步数减少Fewer mean steps in a remembered-location scenario

memory_hint_toolbox · 3 个种子 · 二维网格仿真:平均 56.3→19.3 步;不是全部场景平均收益。memory_hint_toolbox · three seeds · 2D grid simulation: 56.3→19.3 mean steps, not an average gain across all scenarios.

做项目的方法HOW I WORK

把问题做具体,
把结果讲清楚。
Make the problem concrete.
Make the evidence clear.

我习惯从具体任务出发,把问题拆成可以实现和验证的步骤。做完一个系统,还要回头检查:结果从哪里来,换一个条件是否成立,失败又说明了什么。项目页面记录这些过程,也保留做出技术选择时的判断。I start with a concrete task and break it into steps I can implement and test. After building a system, I ask where the result comes from, whether it holds under different conditions, and what failures reveal. The case studies document that process and the reasoning behind the design decisions.

KNOWLEDGE HUB

知识星球Notes & ideas

技术文章、阅读笔记与持续记录。Technical writing, reading notes, and work in progress.

进入知识网站Visit the knowledge hub

LET’S CONNECT

聊聊你正在解决的问题。What are you working on?

工程合作、研究交流、授课邀请,或一个值得投入的职业机会。Engineering collaboration, research, teaching invitations, or a meaningful career opportunity.

发邮件联系Email me